About
My research lies at the intersection of robot learning and representation learning. I am currently focused on robotic manipulation and predictive representation learning, particularly joint-embedding predictive architectures (JEPA) and world models. More broadly, I am interested in reinforcement learning and robot foundation models that enable robots to acquire generalizable skills from large-scale and diverse interaction data.
I am a PhD student at the Matsuo-Iwasawa Laboratory, The University of Tokyo, where I am advised by Yusuke Iwasawa and mentored by Yaonan Zhu. Previously, I completed my master's degree at the Learning Machines Group, Kyoto University, under the supervision of Jun Morimoto.
Publications
-
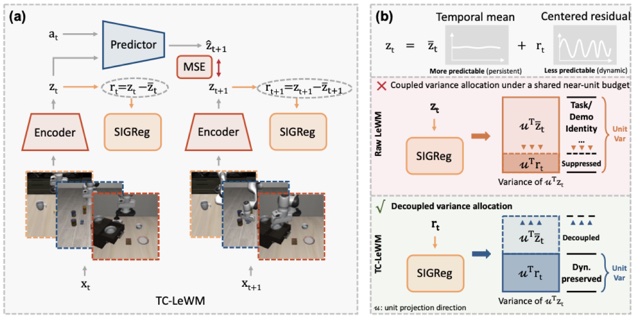
Temporally Centered SIGReg Improves LeWorldModel Representations for Robot Policy Learning
arXiv preprint arXiv:2607.26924, 2026
The LeWorldModel objective biases variance toward the temporally persistent component, suppressing the residual variation that carries robot state and gripper dynamics. Applying SIGReg to temporally centered residuals instead decouples the two and lifts average LIBERO success from 63.6% to 83.8%.
-
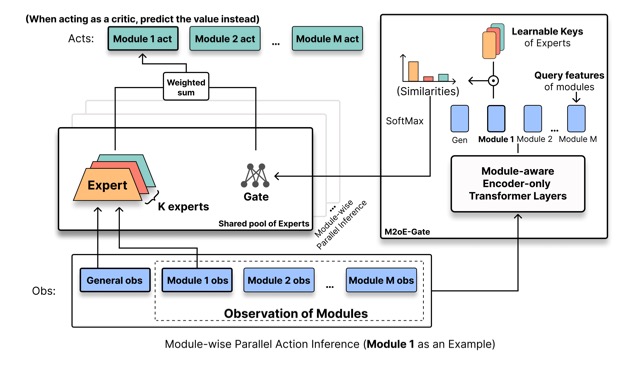
M2oE: Modular Mixture of Experts for Multi-Morphology Reinforcement Learning of Modular Robots
IEEE International Conference on Robotics and Automation (ICRA), 2026
A reinforcement learning backbone that mirrors the robot's own modular structure: a shared pool of experts plus an attention gate that reads inter-module correlations. One policy trains across many morphologies at once, module-wise parallel, without the gradient conflicts that usually follow.
-
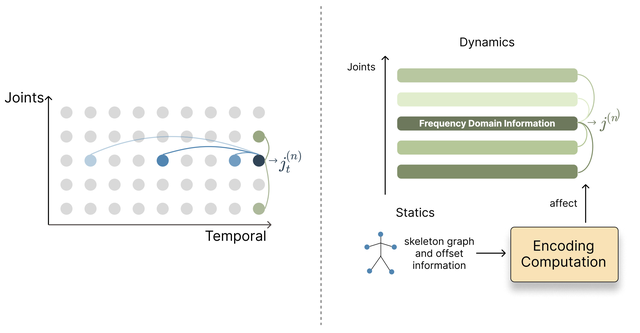
Joint-Aware Transformer: An Inter-Joint Correlation Encoding Transformer for Short-Term 3D Human Motion Prediction
IEEE Access, vol. 12, pp. 156683–156693, 2024
Reconsiders what attention is for in short-term motion prediction. Rather than modelling time, the attention encodes inter-joint correlation from both skeleton dynamics and static structure, while DCT and MLPs handle the temporal axis — reaching state of the art under 400 ms.
Experience
-
Matsuo Institute
Feb 2026 – Mar 2026Research intern. Surveyed and reproduced recent work on vision-language-action models (VLA), human-in-the-loop learning (HIL), and Recap.
-
Ziyan Robotics
Jan 2023 – Mar 2023Research intern. Trained reinforcement learning policies for dexterous hand manipulation.